Detects sponsor logos in F1 broadcast footage with YOLO, as a first step towards measuring each brand's screen time. Zero-shot YOLO-World finds no real logos; a YOLO11s fine-tuned on 69 labelled frames reaches mAP50 0.61 on held-out frames.
Andrew K. Mackay
Machine Learning & AI Engineer · Zaragoza, Spain
Abstract. I am a machine learning engineer with a research background in reinforcement learning and robotics. I hold an MSc in Computer Science from the University of Innsbruck, have published on reinforcement learning for robot navigation, and have put models in front of real users, from eye-tracking diagnostics validated with over 4,000 patients to LLM solutions for industry clients.
I now work as an AI Engineer at MediaRadar, building machine learning pipelines that classify media content. Before that, my work was on LLMs, retrieval and agents, where I care as much about measuring a system as about building it.
Selected work
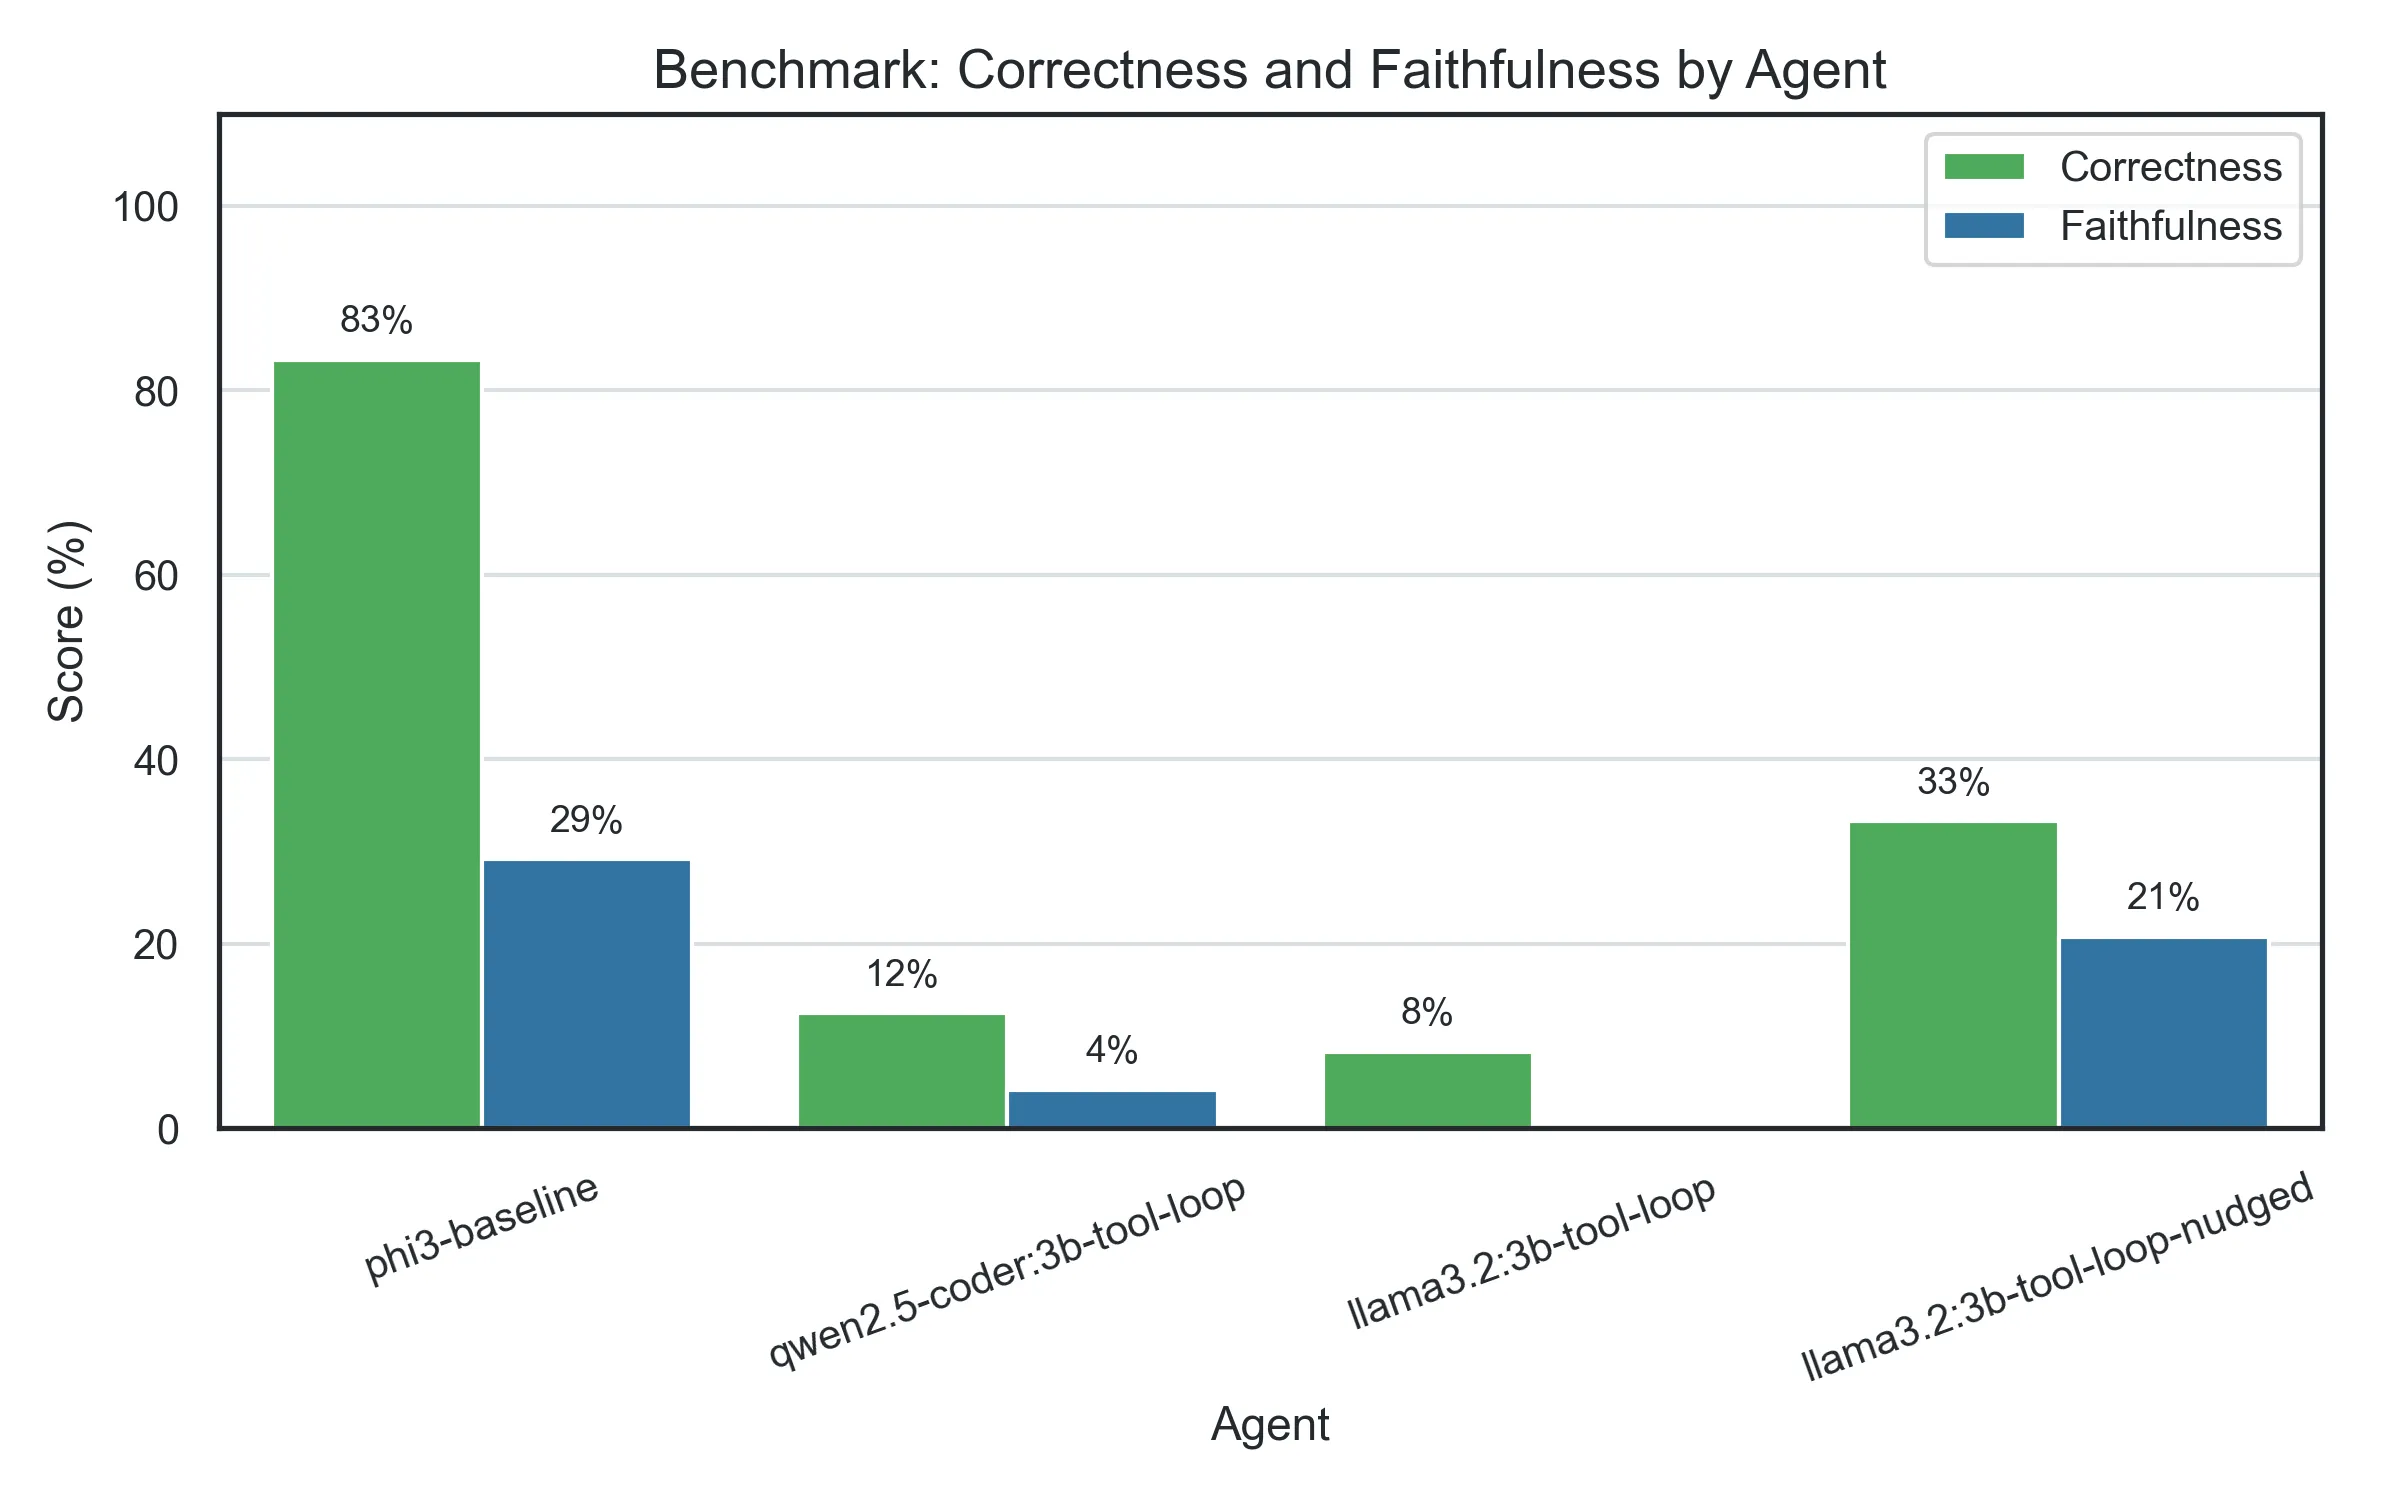
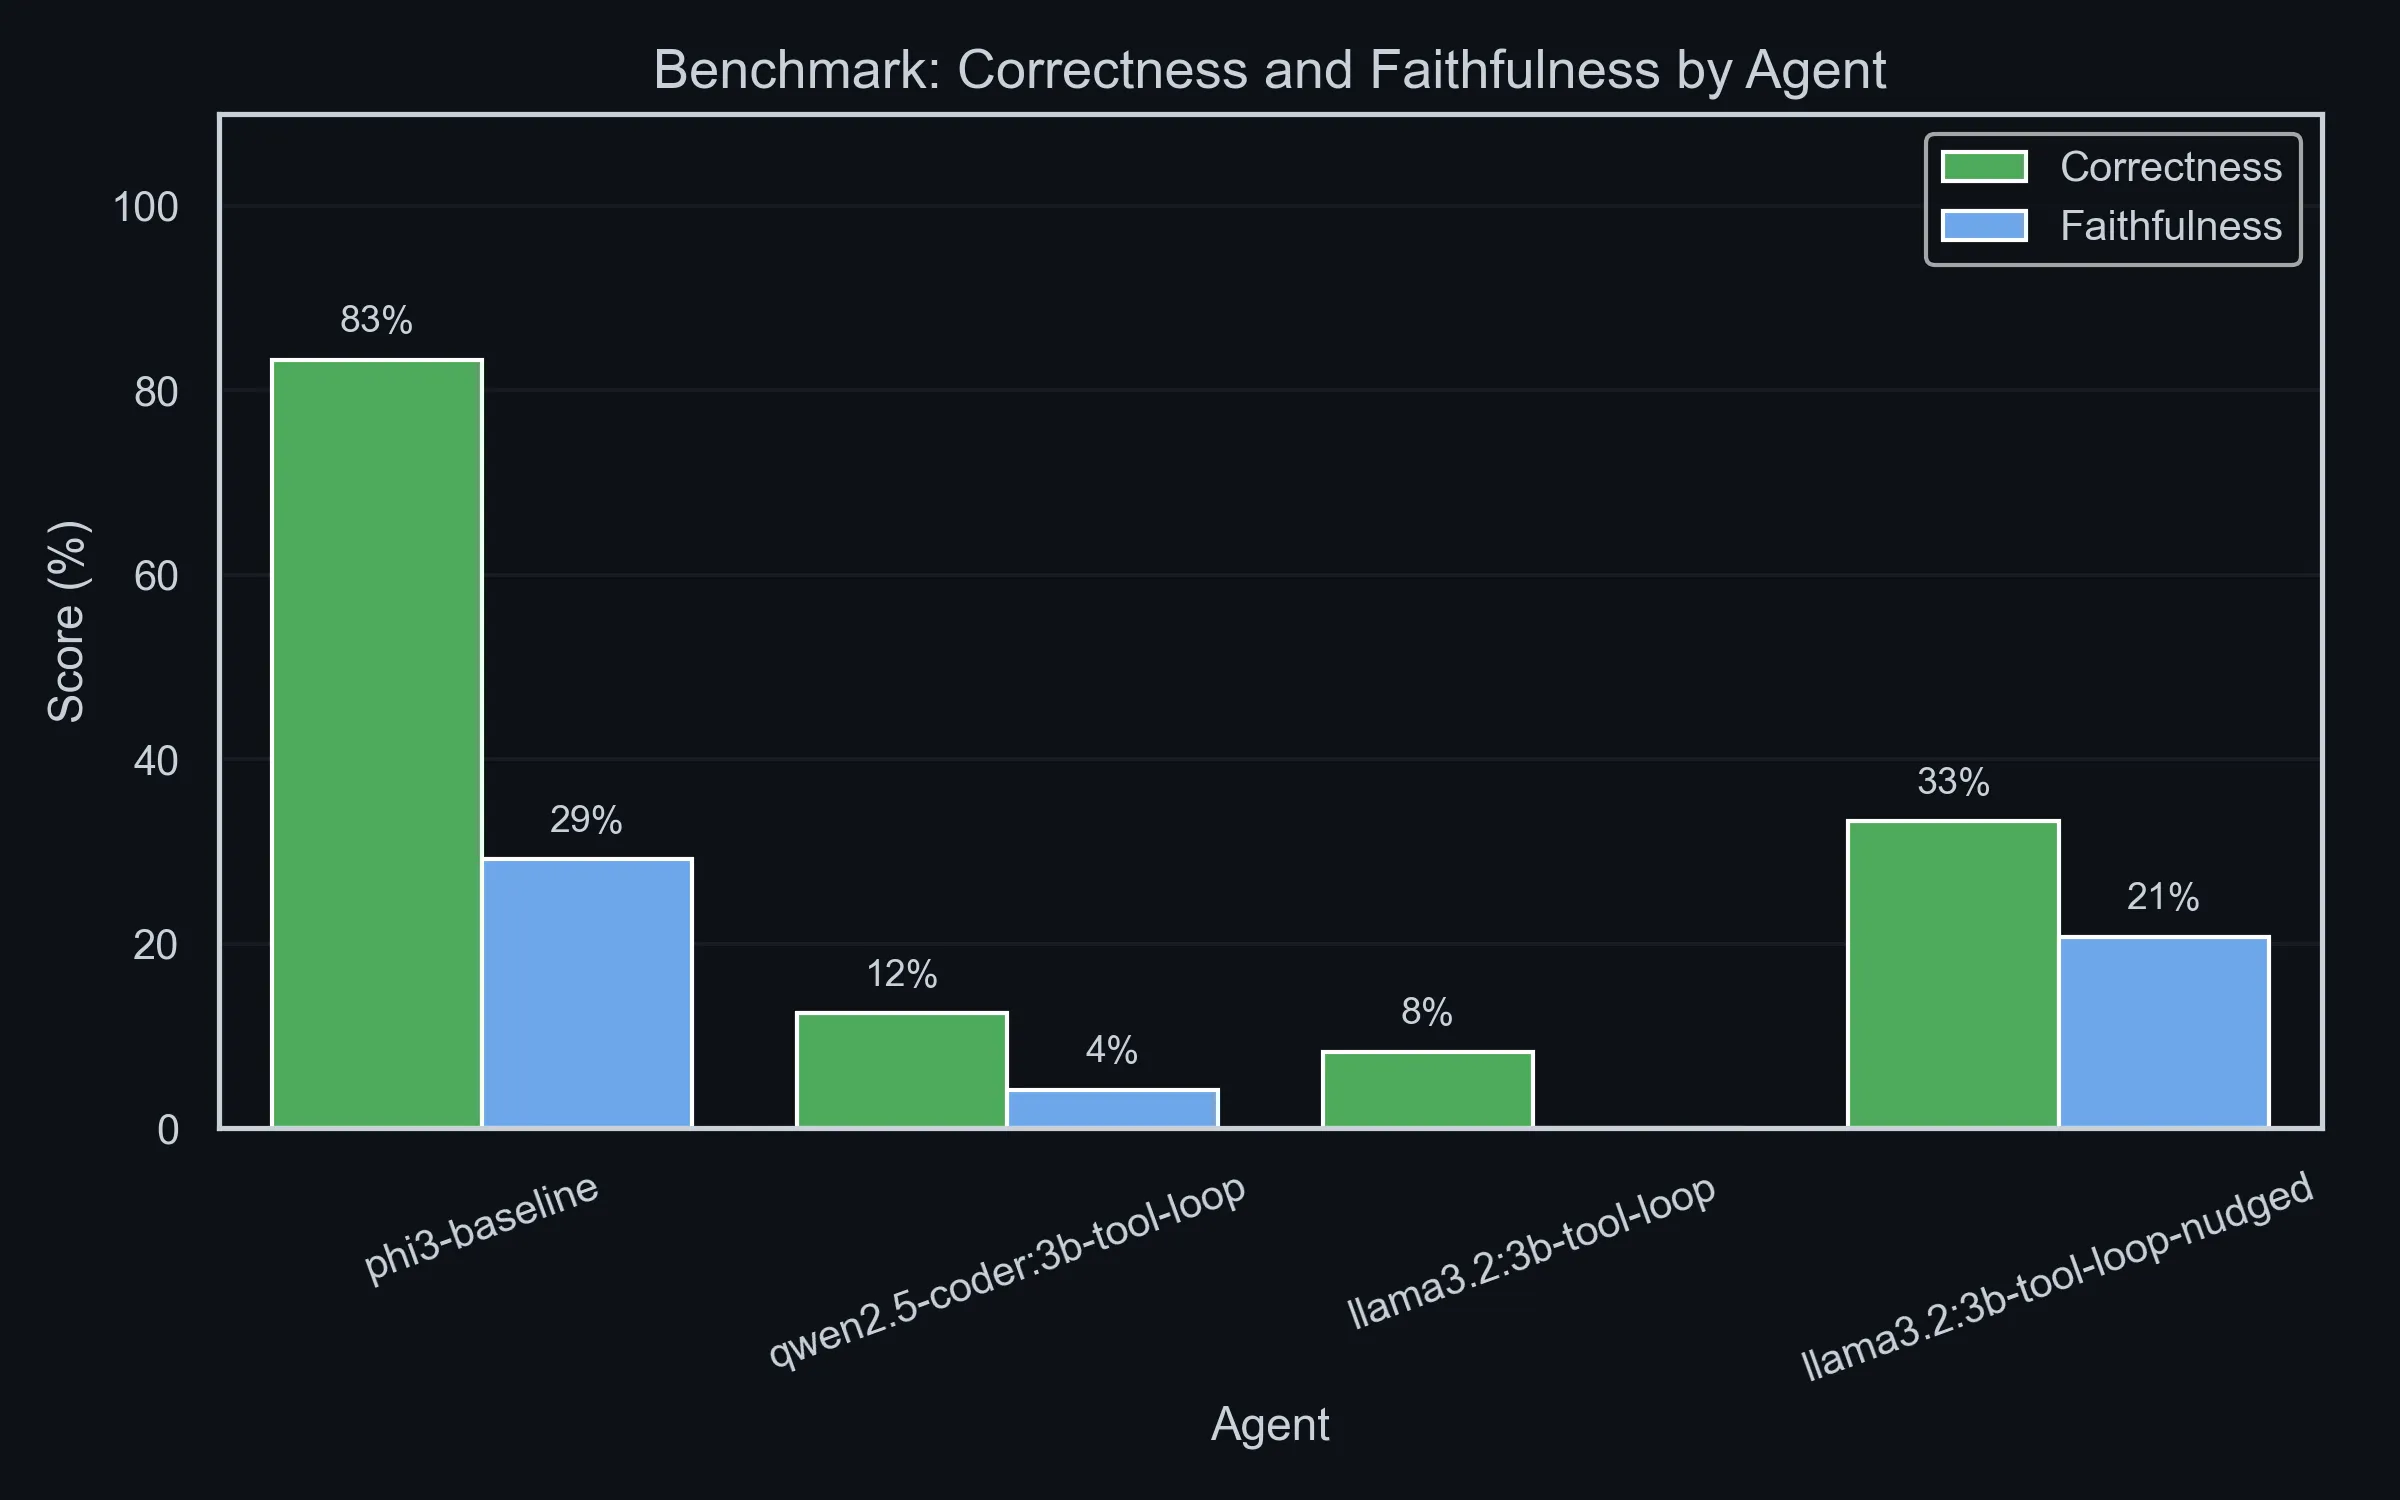
A local assistant that answers programming questions from a code corpus, reviews its own answers and retries when they fall short.
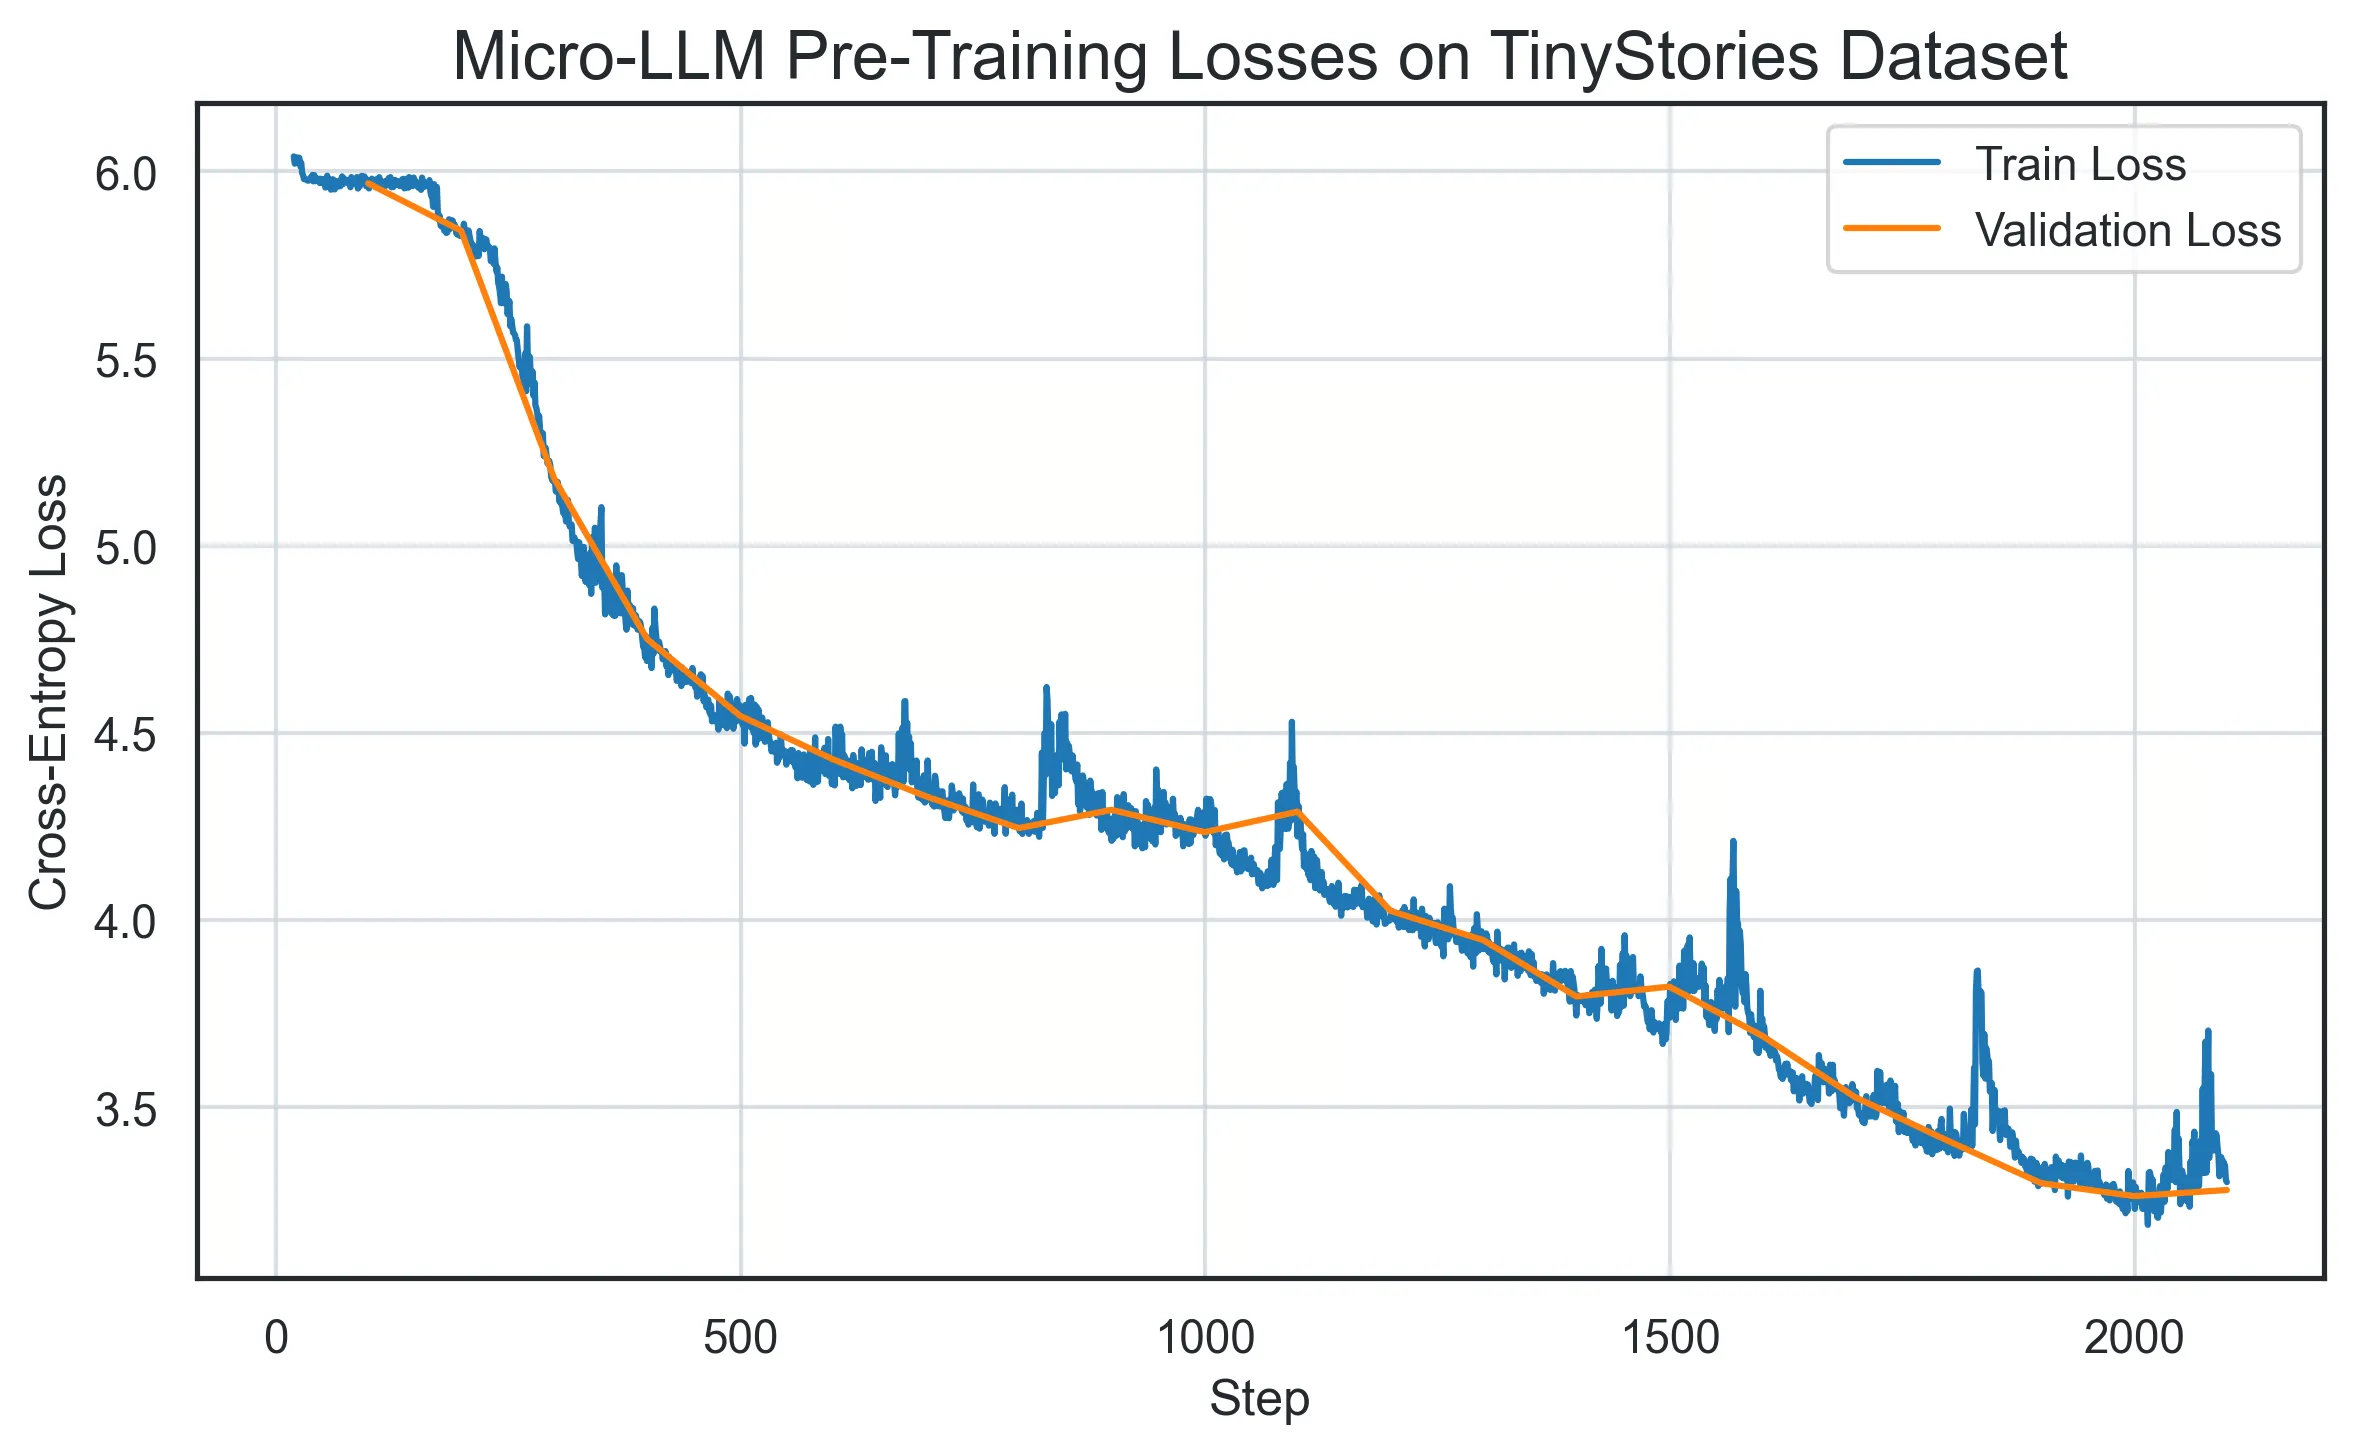
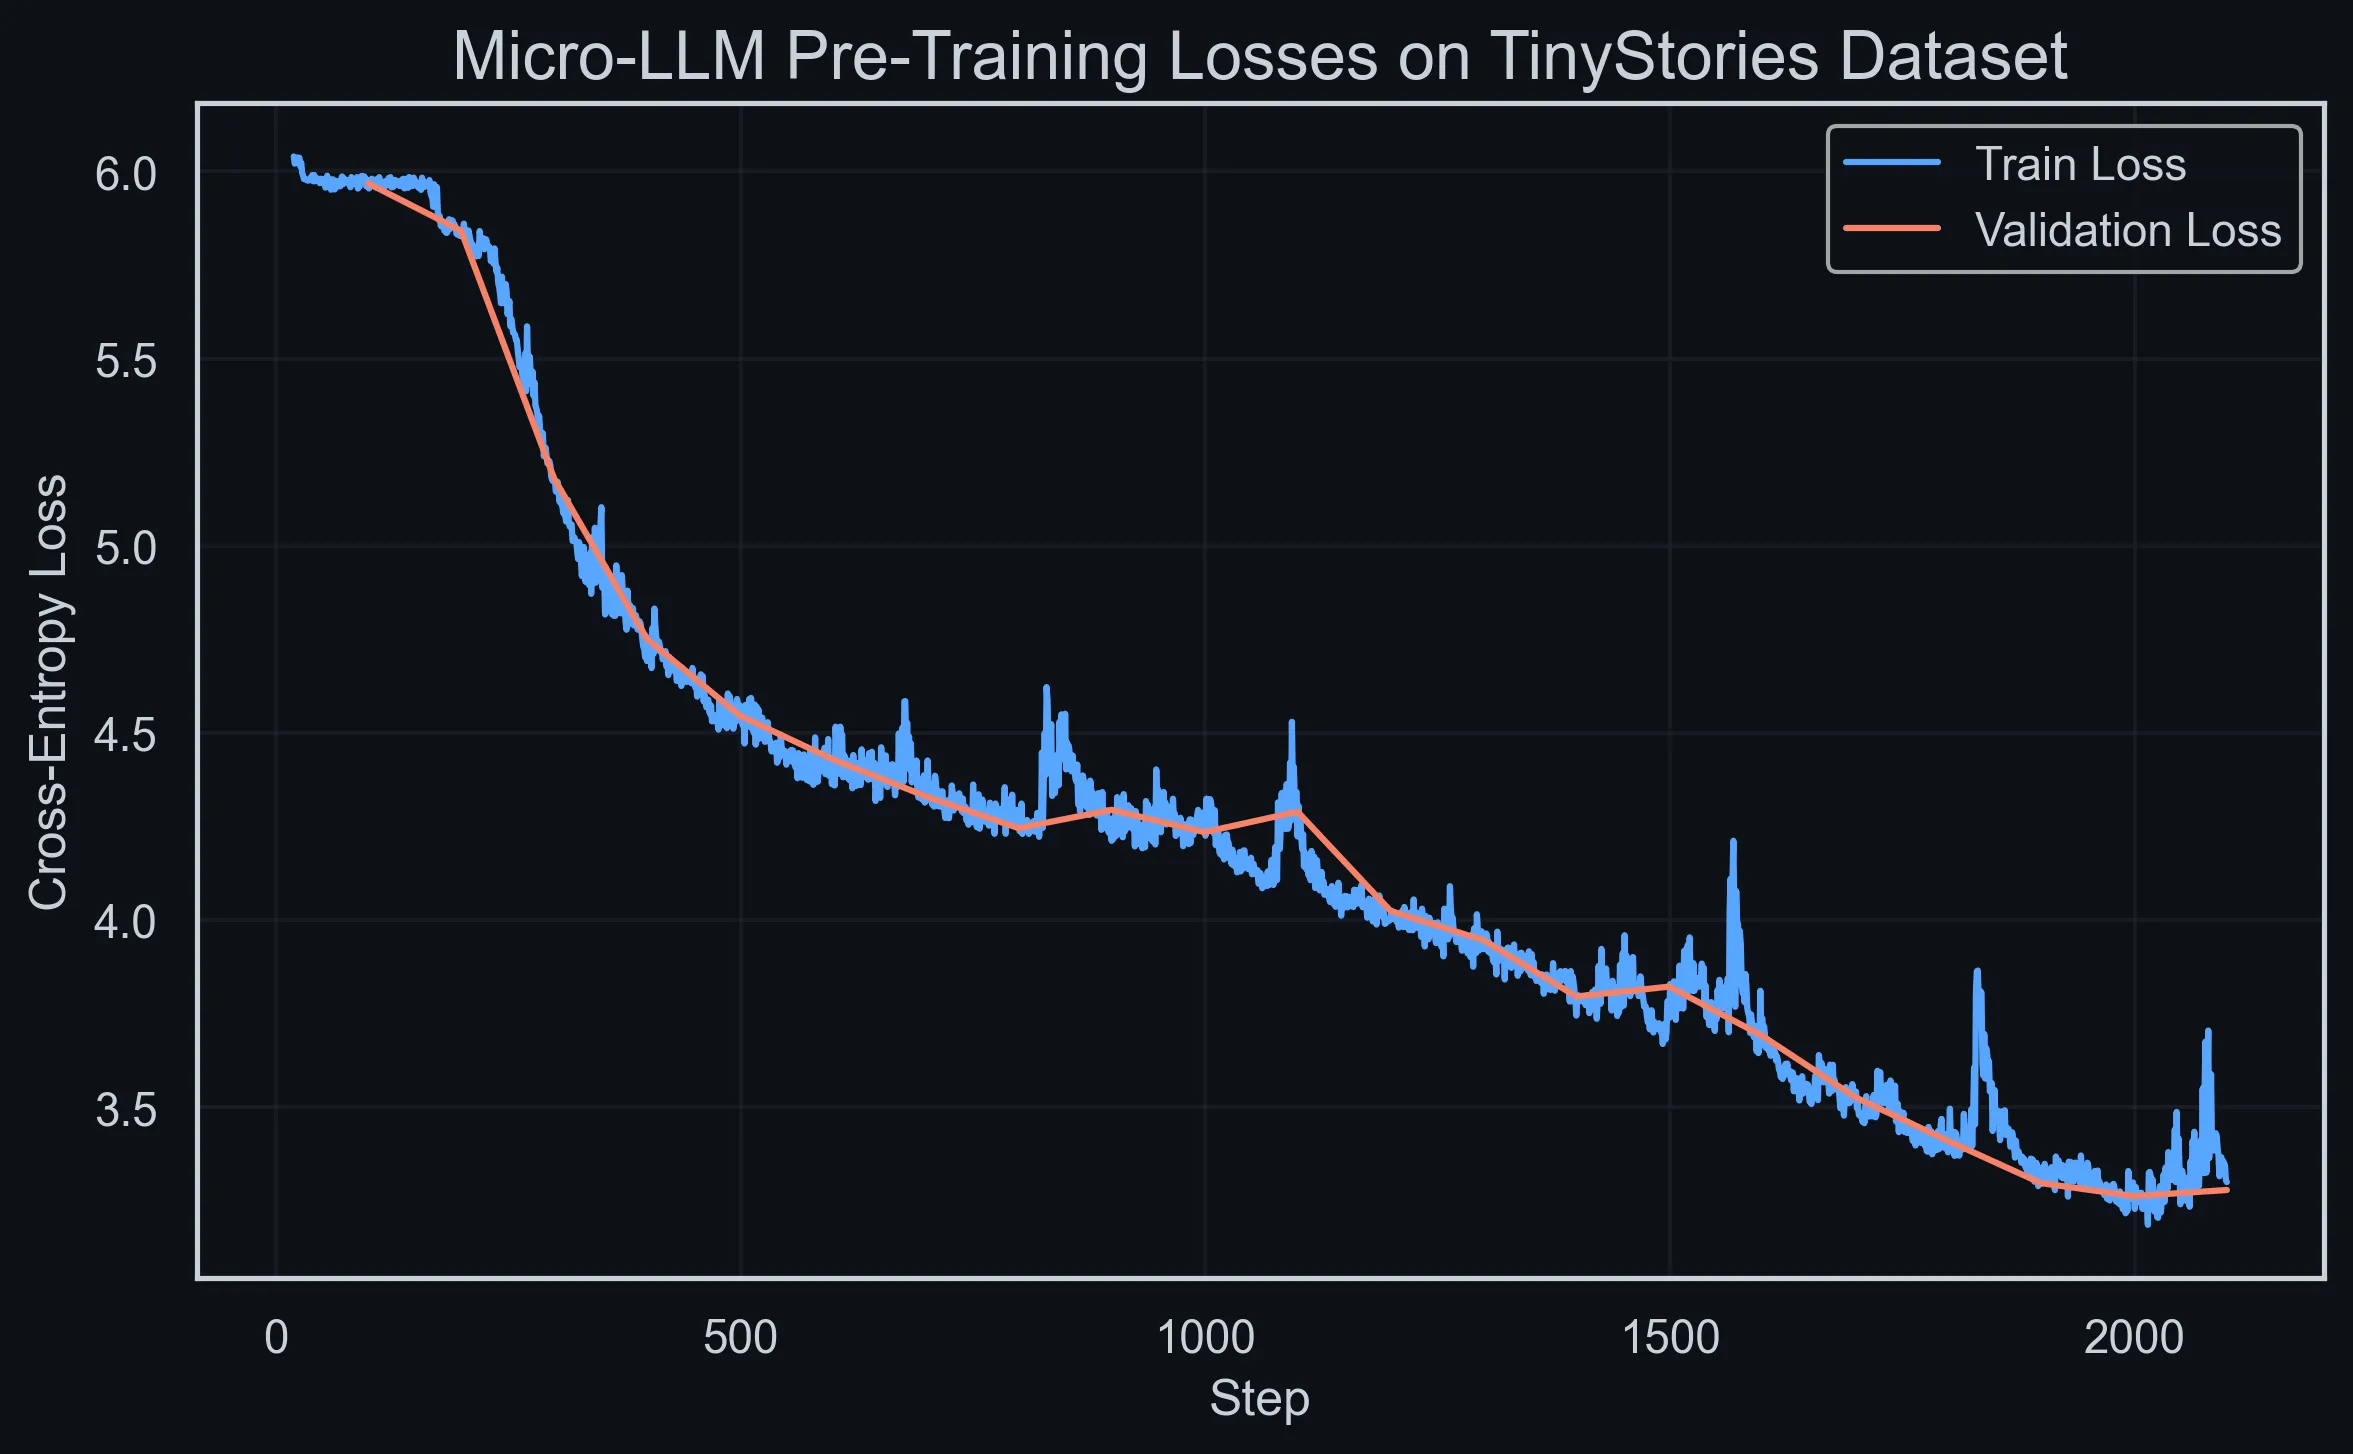
A Llama-style language model written from scratch in PyTorch, small enough to pre-train on a laptop, then fine-tuned with reinforcement learning.
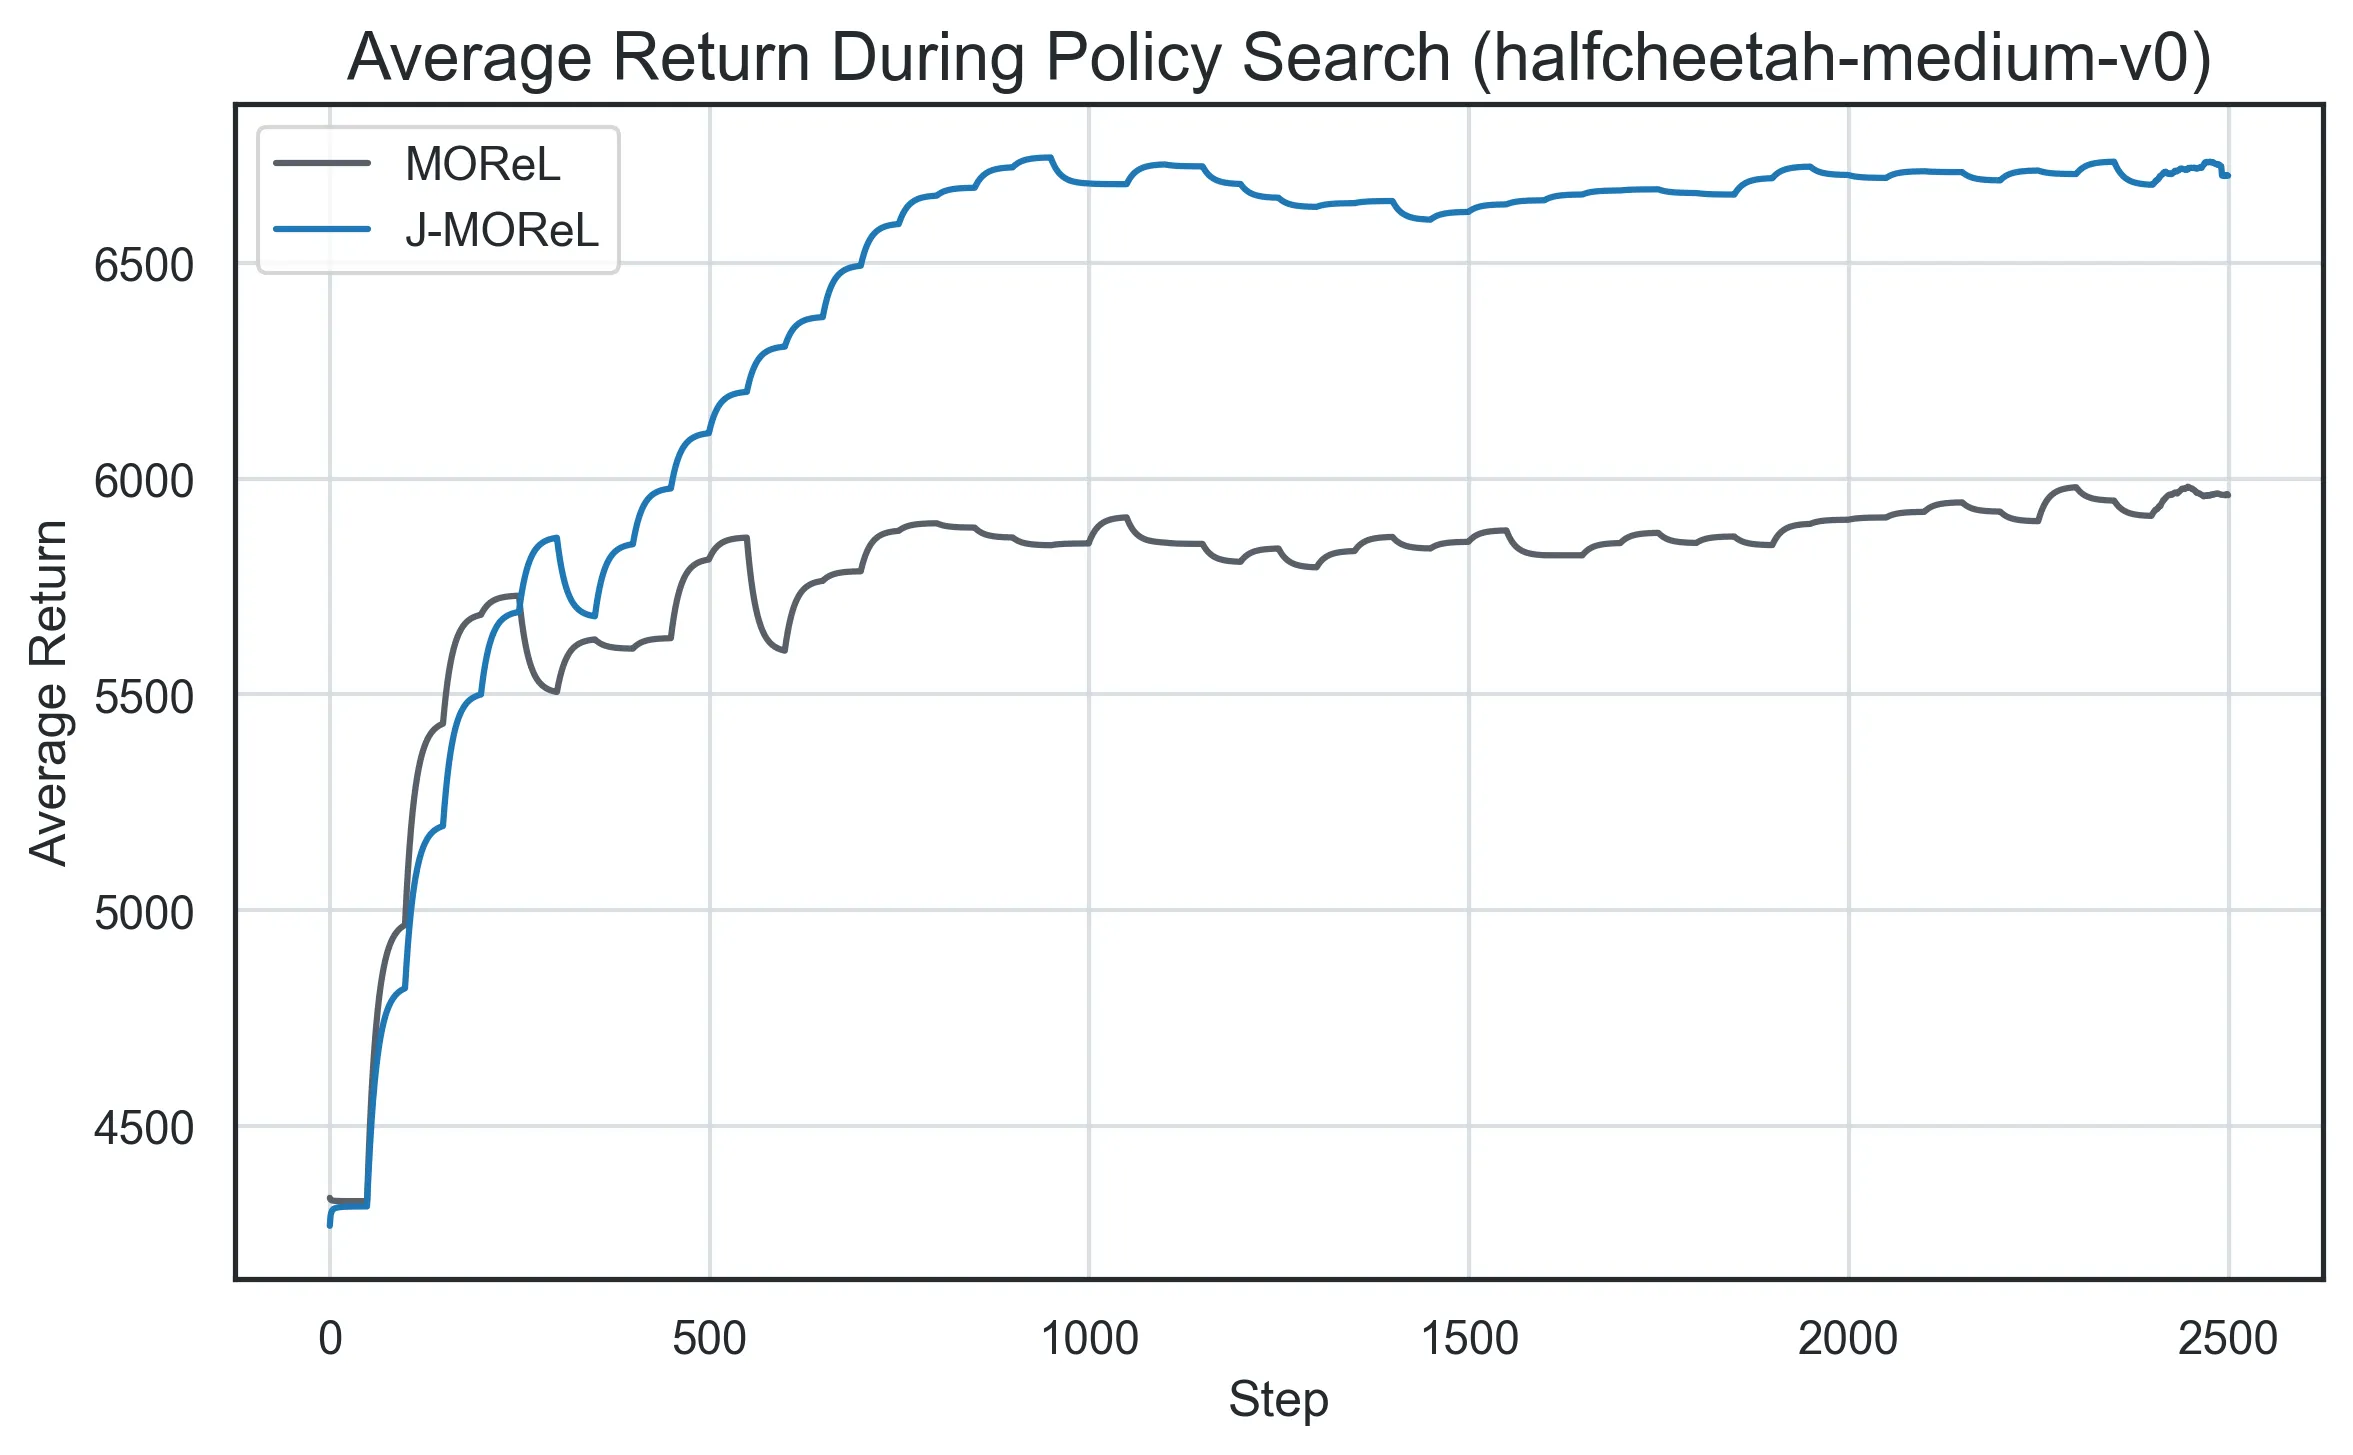
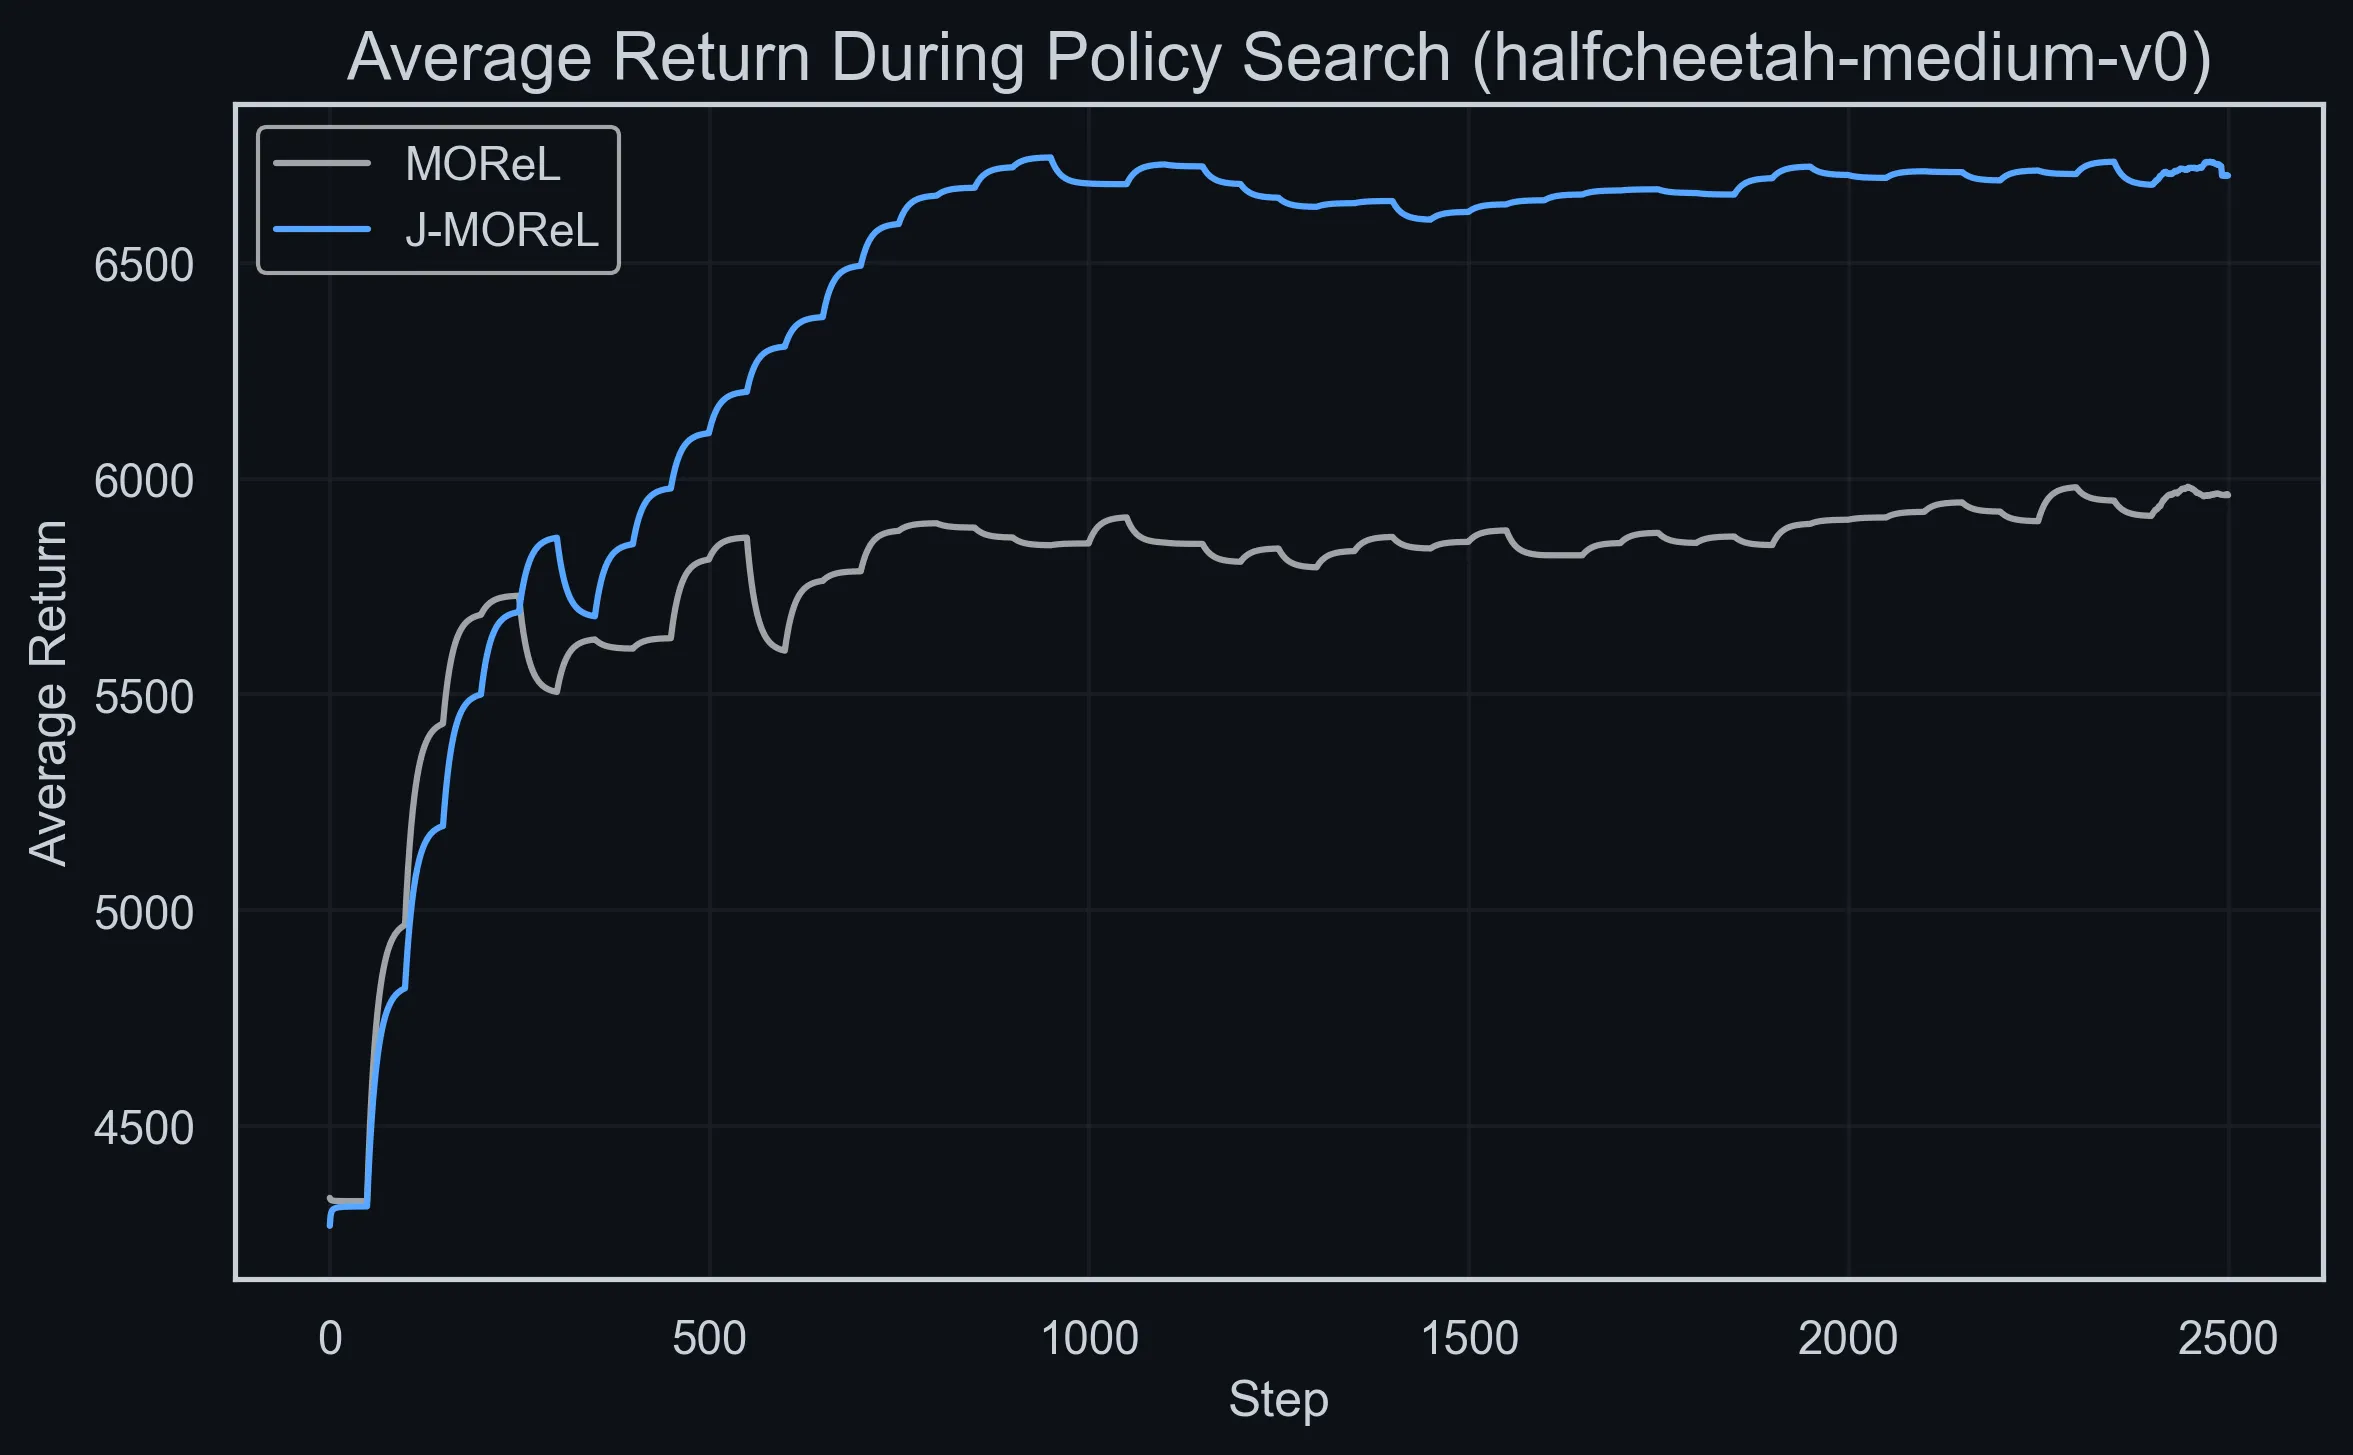
A reimplementation of the MOReL offline reinforcement learning framework with the improvements I proposed in my MSc thesis. It outperforms the original on the D4RL HalfCheetah benchmark.
Experience
AI Engineer
MediaRadar
- Building machine learning pipelines that classify media content, deployed on Kubernetes.
AI Solutions Architect
Multiverse Computing
- Met clients in health, climate, media and manufacturing to understand their problems, then designed LLM-based solutions: model compression, fine-tuning, retrieval-augmented generation and agent orchestration, plus computer vision and Whisper speech pipelines.
- Wrote the technical side of proposals for private companies and of public R&D consortium bids, including EU Horizon and Spain’s Misiones programme.
- Benchmarked models and built demos to validate proposed solutions.
Research Software Engineer
Aragón Health Research Institute (IIS Aragón)
- Built core components in C# and Kotlin for TrackAI, a platform that uses eye tracking to assess visual function in patients who cannot take a standard eye test, such as infants. It has been validated with more than 4,000 patients.
- Deployed deep-learning gaze-estimation models to mobile hardware (Huawei NPU) through an Android app.
- Worked with clinicians and researchers to replace manual evaluation steps with automated diagnostic tools.
Research Intern
University of Zaragoza, Graphics & Imaging Lab
- Studied how visual perception develops during infancy through eye-tracking experiments.
- Processed high-frequency gaze recordings into visualisations the research group could use for large-scale analysis.
Machine Learning Intern
Hiberus Tecnología
- Built binary classifiers (XGBoost, neural networks) that predict customer conversion from real sales data, with feature-importance analysis, and presented the results to the R&D team.
- Developed blockchain web applications on Ethereum smart contracts.
Education
MSc in Computer Science
University of Innsbruck
Specialisation in Robotics, Perception and Interaction. Final grade: Excellent, 96/100.
BEng in Computer Science Engineering
University of Zaragoza
Specialisation in Computing.
Research
RL-DOVS: Reinforcement Learning for Autonomous Robot Navigation in Dynamic Environments
A. K. Mackay, L. Riazuelo, L. Montano. Sensors 22(10), 3847, 2022.
A reinforcement learning planner for service robots that navigate among people moving unpredictably. Instead of learning from raw lidar or camera data, the agent sees the scene as a dynamic object velocity space (DOVS): which velocities are safe for the robot, given its kinodynamic constraints and the obstacles’ motion. This representation makes training faster than learning from raw sensors.
BibTeX
@article{mackay2022rldovs,
  title   = {{RL-DOVS}: Reinforcement Learning for Autonomous Robot Navigation in Dynamic Environments},
  author  = {Mackay, Andrew K. and Riazuelo, Luis and Montano, Luis},
  journal = {Sensors},
  volume  = {22},
  number  = {10},
  pages   = {3847},
  year    = {2022},
  doi     = {10.3390/s22103847}
}Model-Based Reinforcement Learning: Optimizing Action Choice on Learned Dynamics
MSc thesis, University of Innsbruck. Awarded the highest grade.
Learns a model of the environment’s dynamics from offline data with neural-network ensembles, then uses it to choose actions while penalising predictions the ensemble disagrees on. The work is public as three projects: J-MOReL, an improved reimplementation of the MOReL offline RL framework; MBiCEM, a trajectory planner that runs iCEM on learned models; and the dynamics ensembles both are built on.
Reinforcement Learning Applied to Autonomous Multi-Robot Navigation Systems in Dynamic Environments
BEng thesis, University of Zaragoza. Extended into the RL-DOVS journal article.
Skills and languages
- ML & LLMs
- PyTorch, Hugging Face Transformers, LangChain, scikit-learn, XGBoost, Ultralytics YOLO, OpenCV, Reinforcement learning
- Data
- Databricks, PySpark, SQL, Pandas, Qdrant
- MLOps & cloud
- Docker, MLflow, FastAPI, GCP (Cloud Run, IAM, Artifact Registry, Secret Manager), CI/CD, Git, Linux
- Languages
- Python, C++, C#, Kotlin, Java, JavaScript
- Visualisation
- Streamlit, Tableau, Matplotlib, Seaborn
- Spoken
- Spanish (native), English (fluent, Cambridge C2 Proficiency), German (A1)
Contact
Working as an AI Engineer at MediaRadar. The quickest way to reach me is by email at [email protected]. My code is on GitHub, and I am also on LinkedIn.